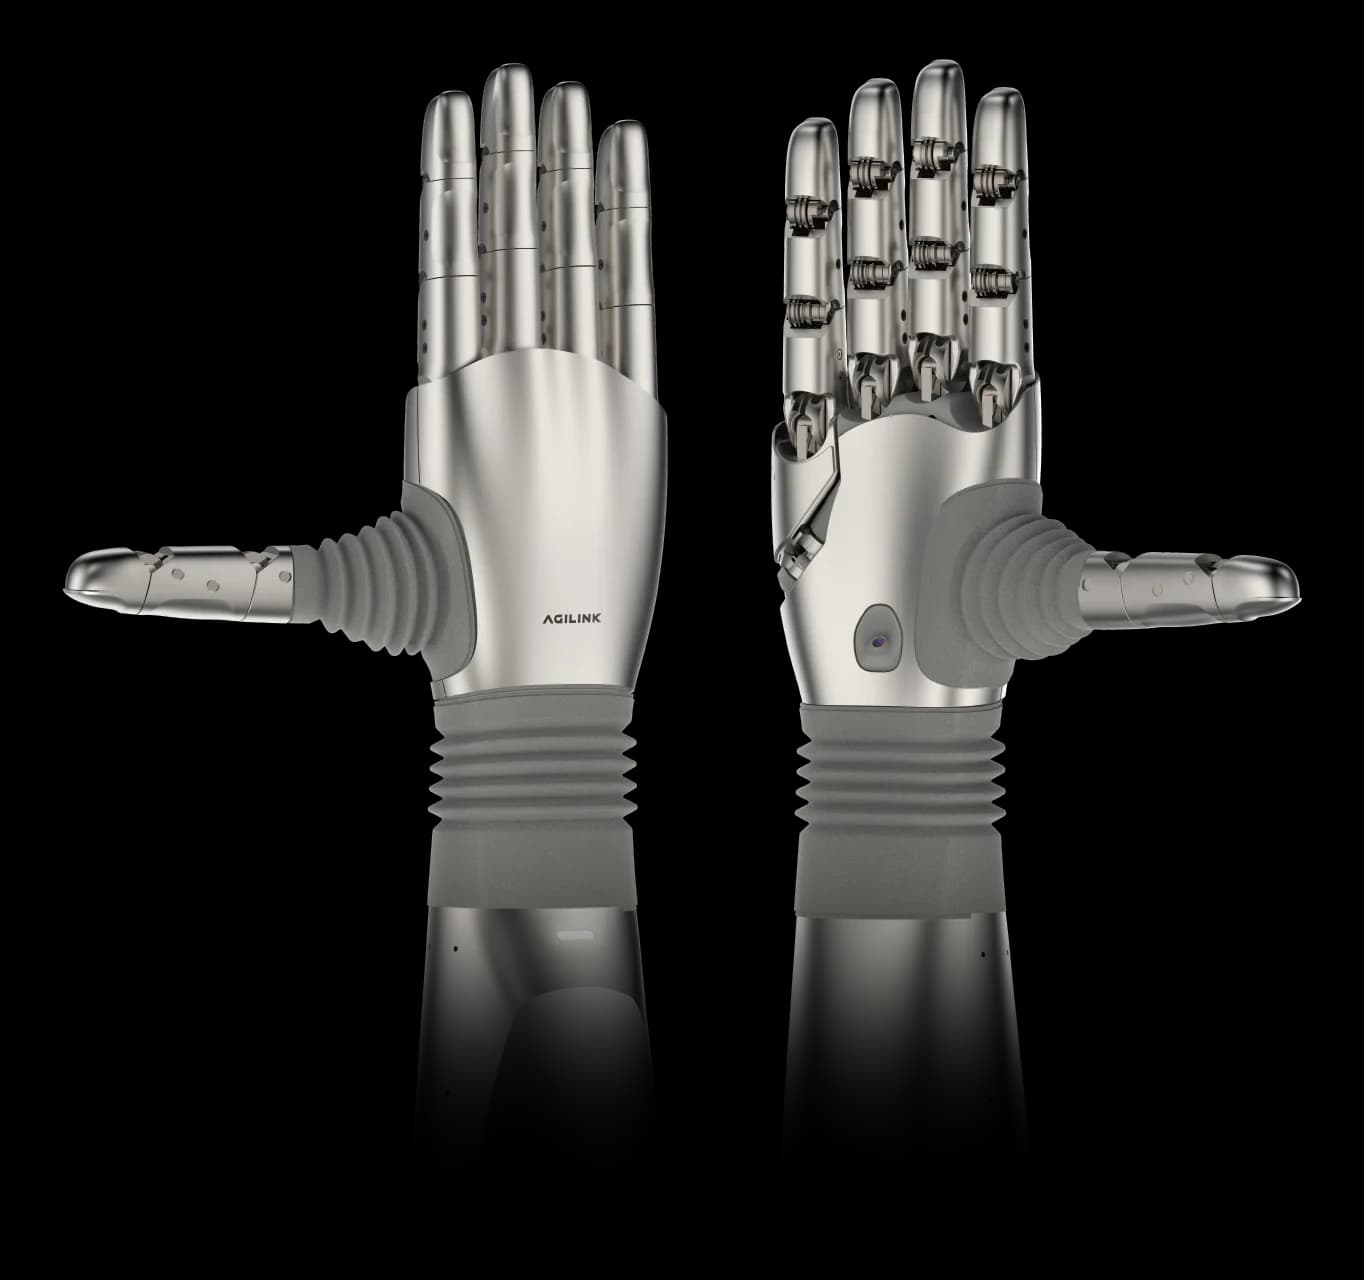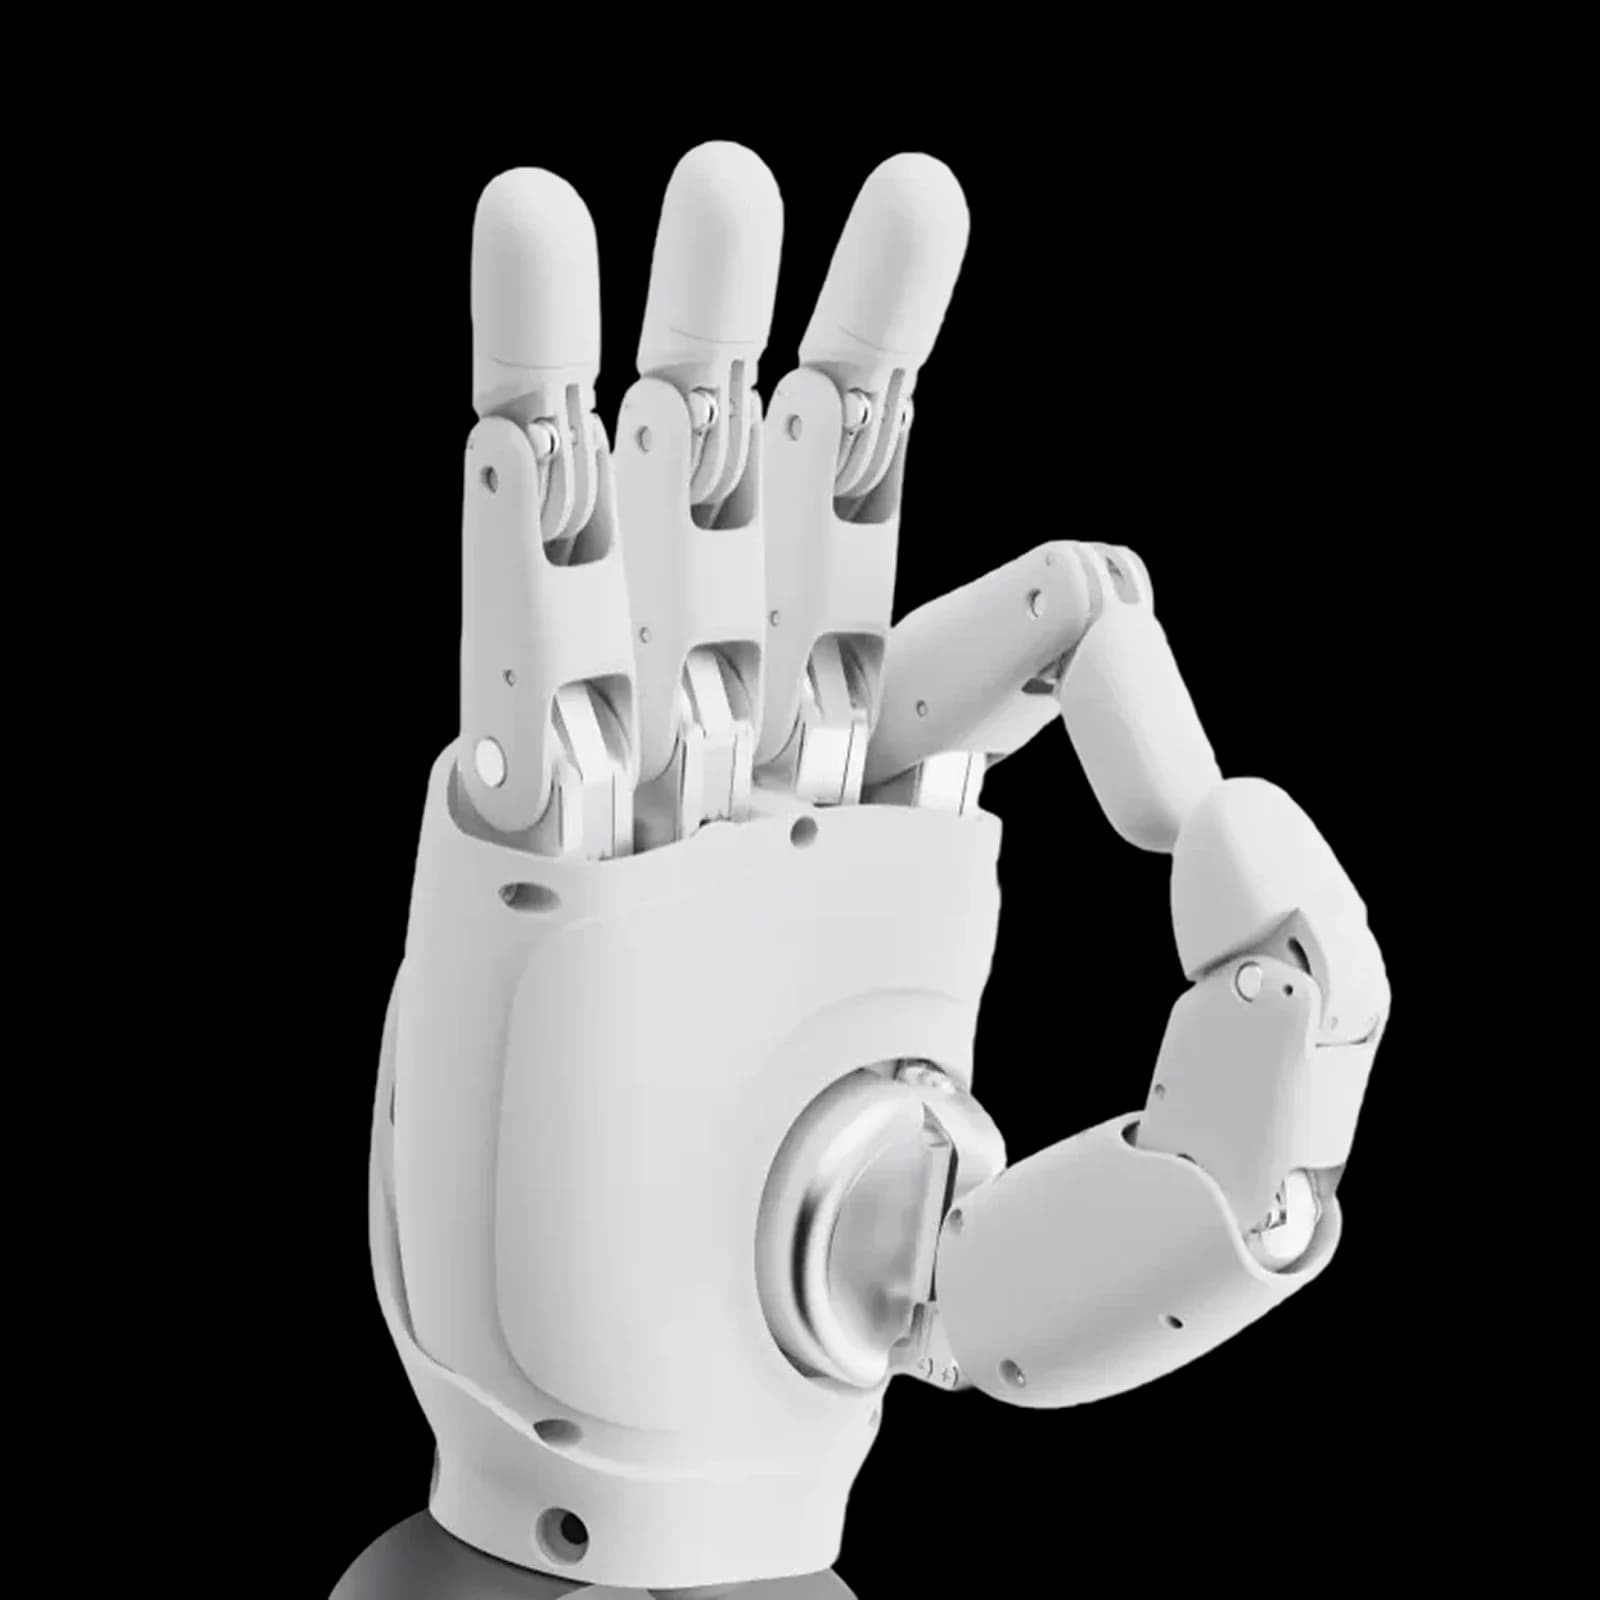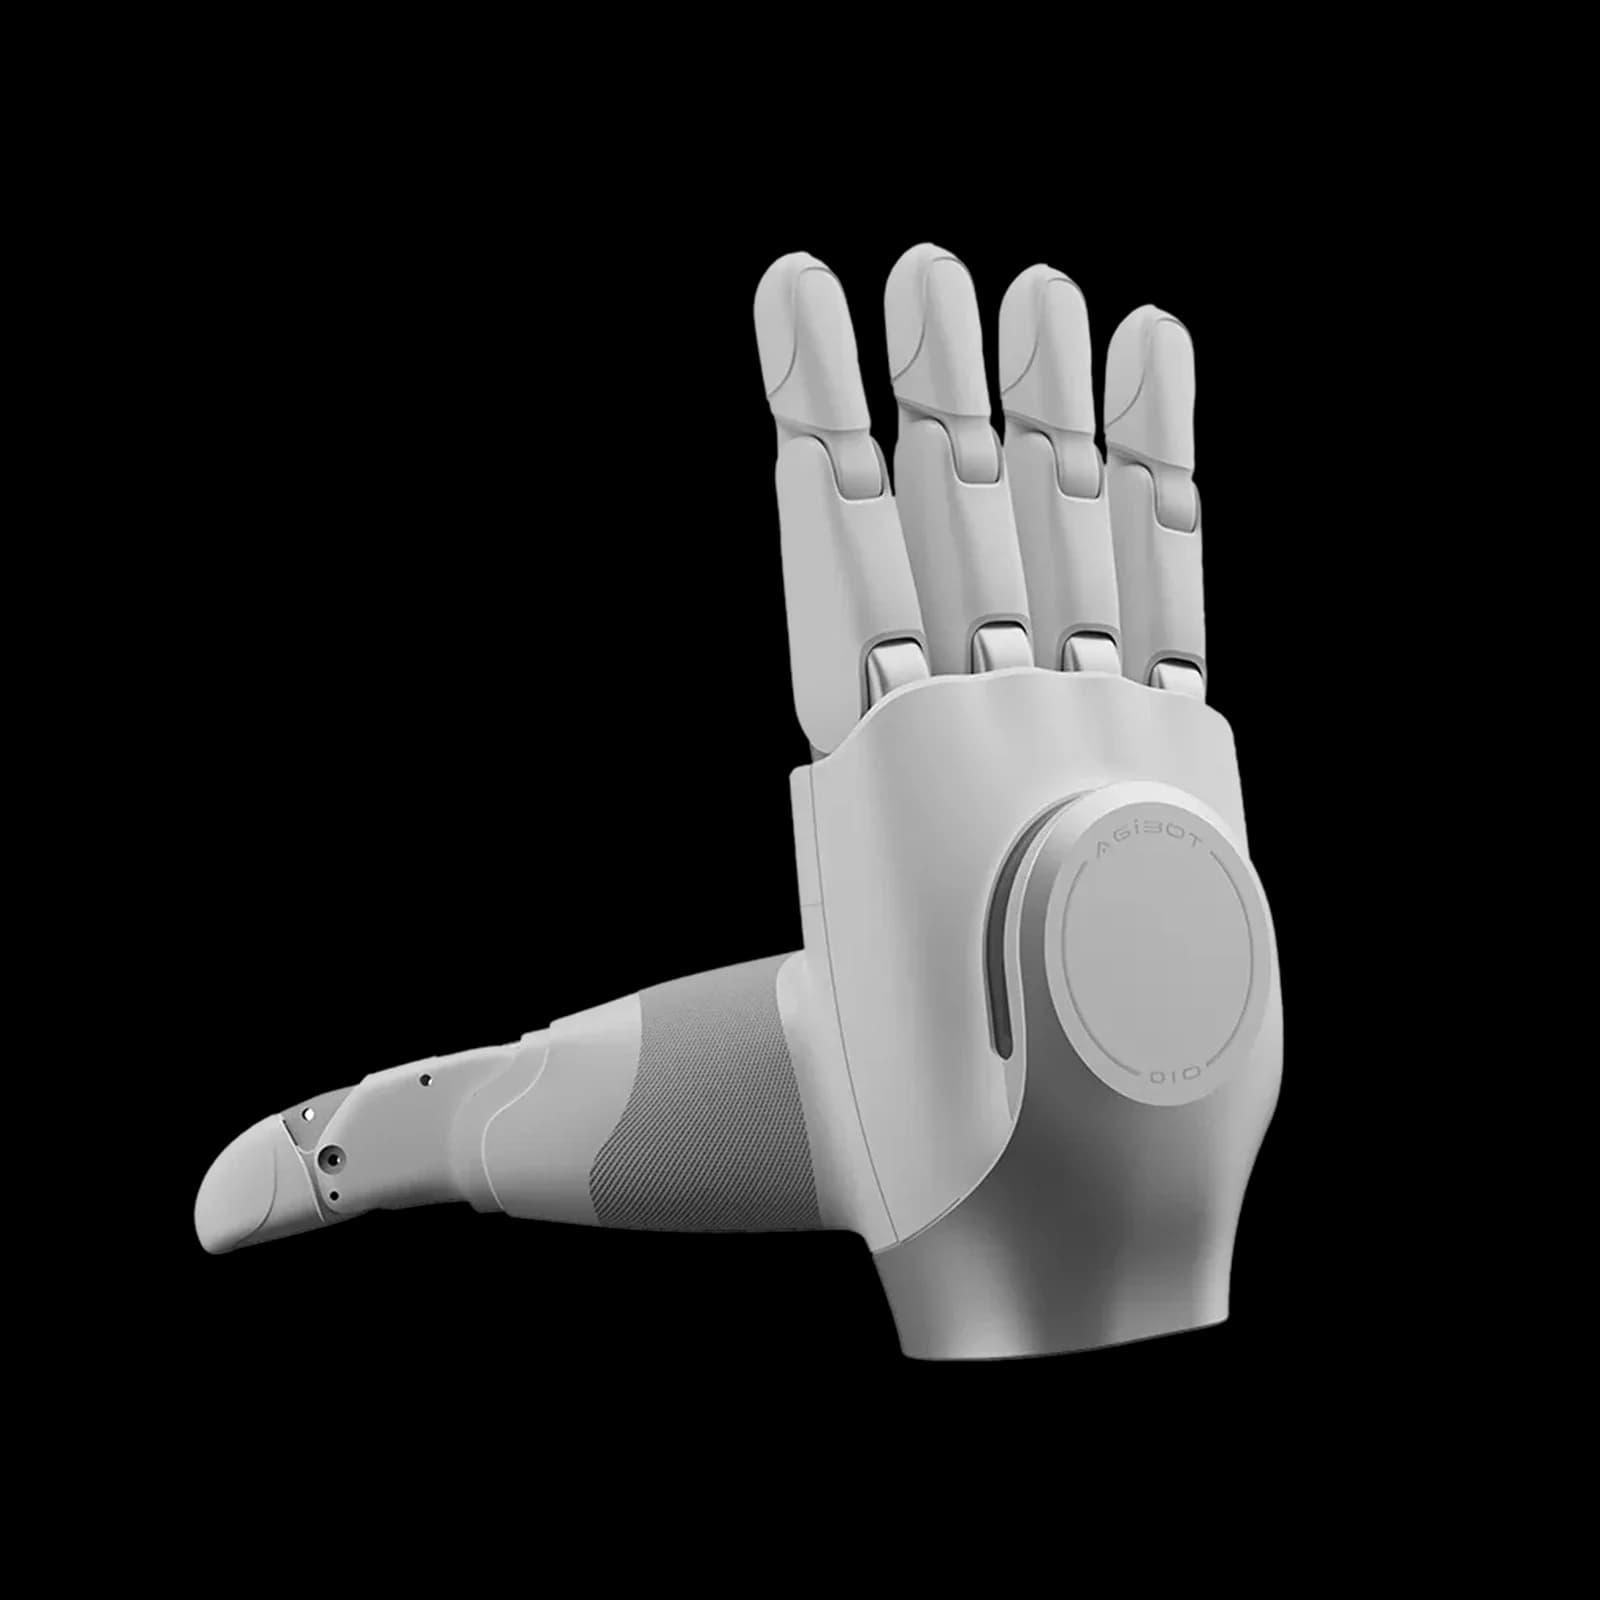
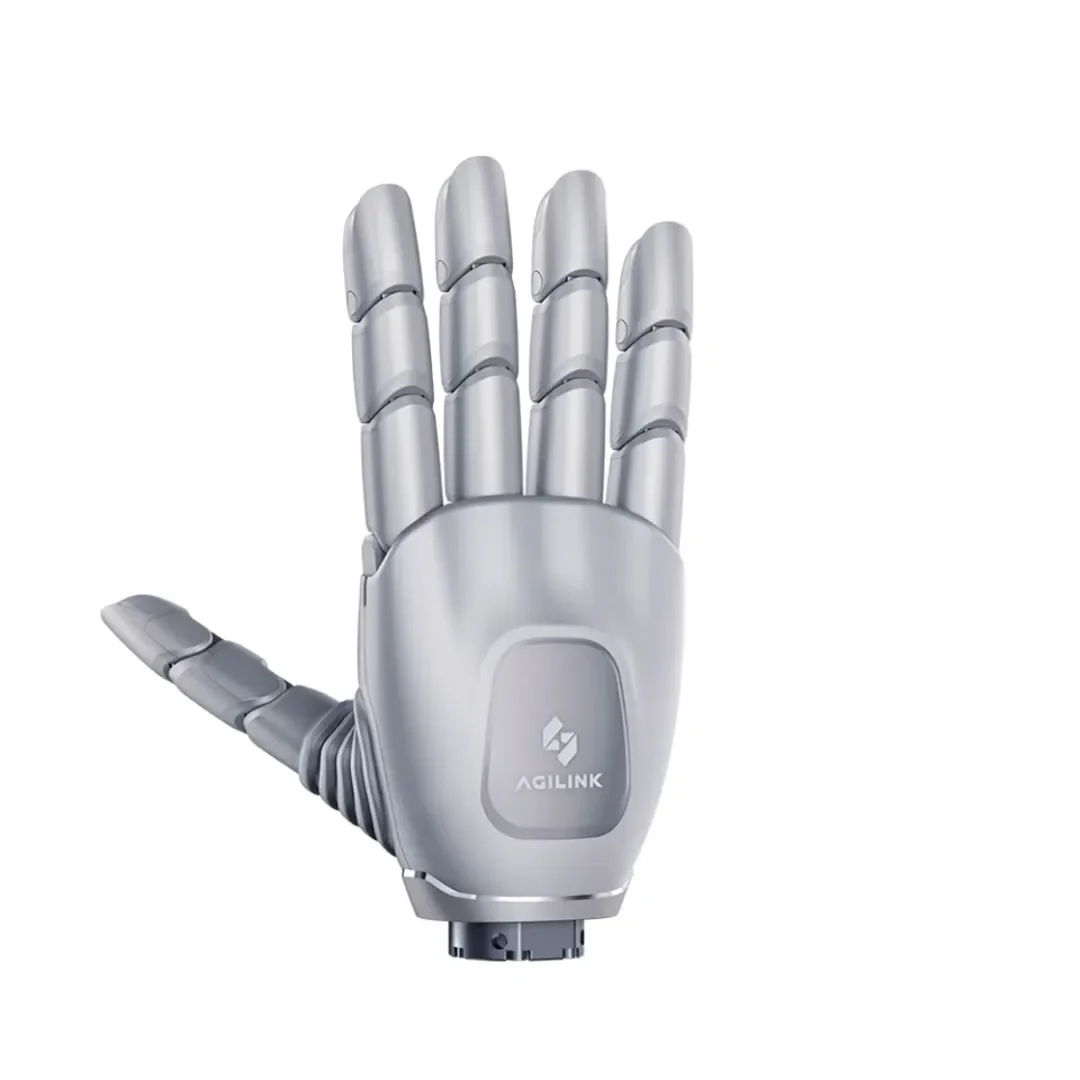
OmniHand 3 Ultra-M
Develop a training or teleoperation brief around the direct-drive Ultra-M hand. Verify the supplied tactile and mounting configuration.
- Direct drive: connect the documented hand design to the training and teleoperation brief
- Vision-based fingertip tactile sensing described at launch: review the fingertip sensing configuration needed for the project
- Palm tactile array described at launch: distinguish the palm sensing claim from fingertip sensing; delivered inclusions need confirmation
For US delivery inquiries, include your state and intended use. We confirm configuration, pricing, availability and lawful supply before sending your quote or invoice.
A closer look.
Published specifications describe the cited manufacturer configuration. Your supplied configuration is confirmed in your quote.
- Active degrees of freedom
- 20Source
- Mass
- 630 gSource
- Whole-hand gripping load
- Up to 5 kg (launch gripping claim; not robot-arm payload)Source
- Typical open/close time
- 0.3 secondsSource
- Repeatability
- ±0.2 mm (launch claim)Source
Configuration and reference notes
Gripping load is not an arbitrary object or robot-arm payload guarantee. Handedness, mounting, power, software and delivered tactile configuration remain pending.
Manufacturer reference tables.
Open the original parameter tables to compare documented versions. Source rows, units and conditions are retained; different versions are not merged into a promised configuration.
These are manufacturer references, not confirmation of your delivered hardware, warranty, field performance or event suitability. Final configuration and terms are agreed in your quote.
Brochure — OmniHand 3 Ultra-M — complete Specifications grid
Document: AGIBOT-Product-Brochure-20260722.pdf
Source model labels: OmniHand 3 Ultra-M
Source location: physical PDF page 17
Source qualifications
- Brochure Payload wording is a hand reference; S06 describes whole-hand gripping load, not robot-arm payload or an arbitrary-object guarantee.
| DoF | 20 Active |
|---|---|
| Dimensions | 189.5*88.5*40mm |
| Weight | 630 g |
| Payload | 5kg |
| Opening/ Closing Time (Typ.) | 0.3 s |
| Repetitive Positioning Accuracy | ±0.2 mm |
| Tactile Sensor | Fingertip: Vision-based tactile sensor Palm: 3D tactile sensor |
| Communication Interface | CANFD/ RS485/ Ethercat |
Manufacturer reference only. This table does not establish the delivered configuration, inclusions, certification, warranty, field performance or event suitability. Preserve source conditions and footnotes when displaying it.
Open manufacturer source — page 17From the right configuration to a clear quote.
Tell us your model, intended use and timeline. We review the accessories and delivery requirements with you, then send a quote or invoice for the agreed configuration.
Start an inquiry- Share your requirements
Model, intended use and timeline.
- Review the configuration
Accessories, compatibility and delivery.
- Receive your quote
Agreed scope before a quote or invoice.