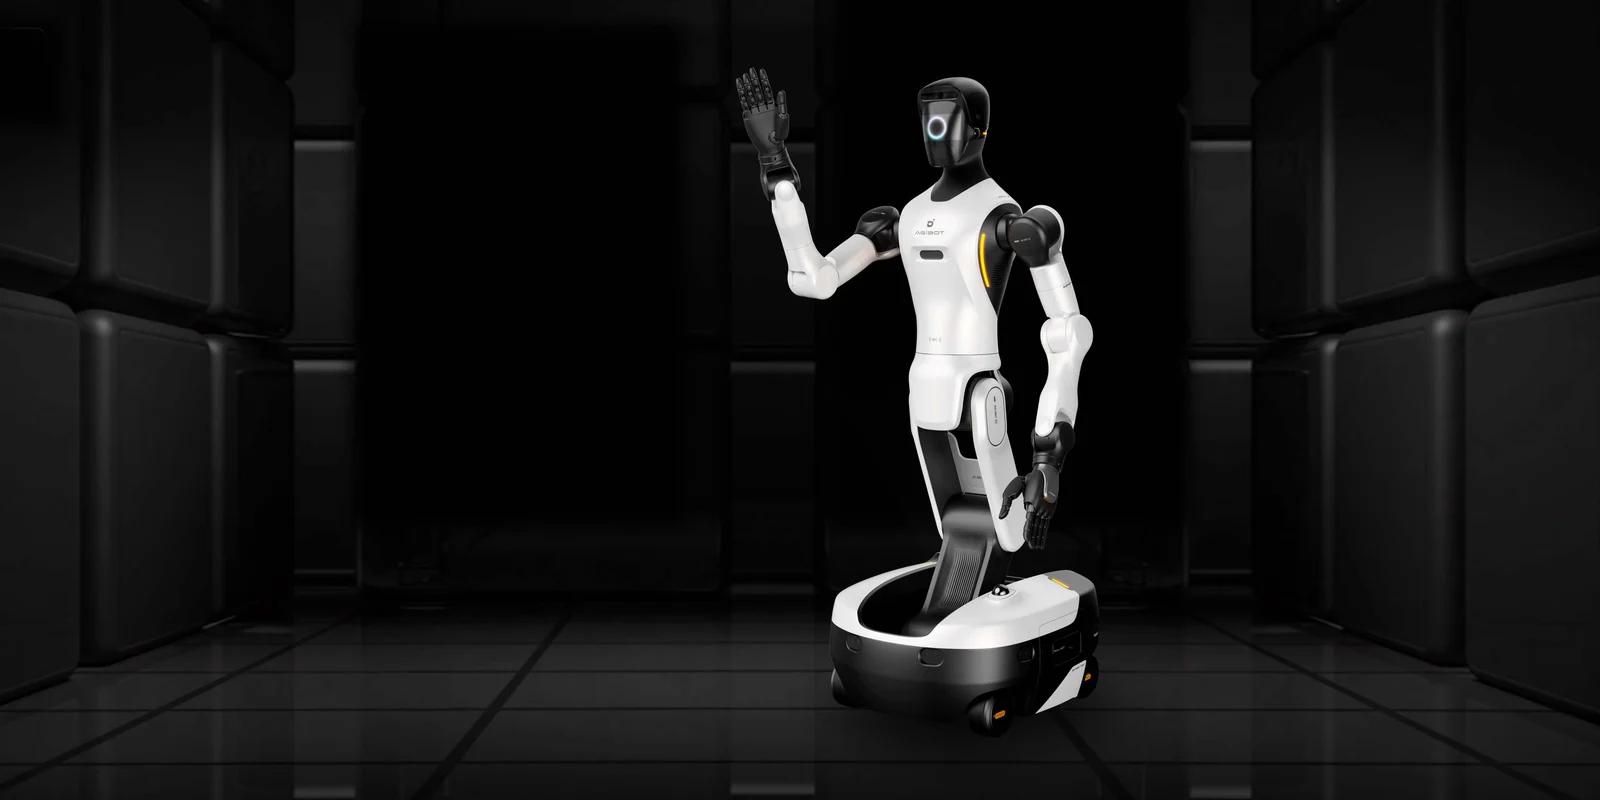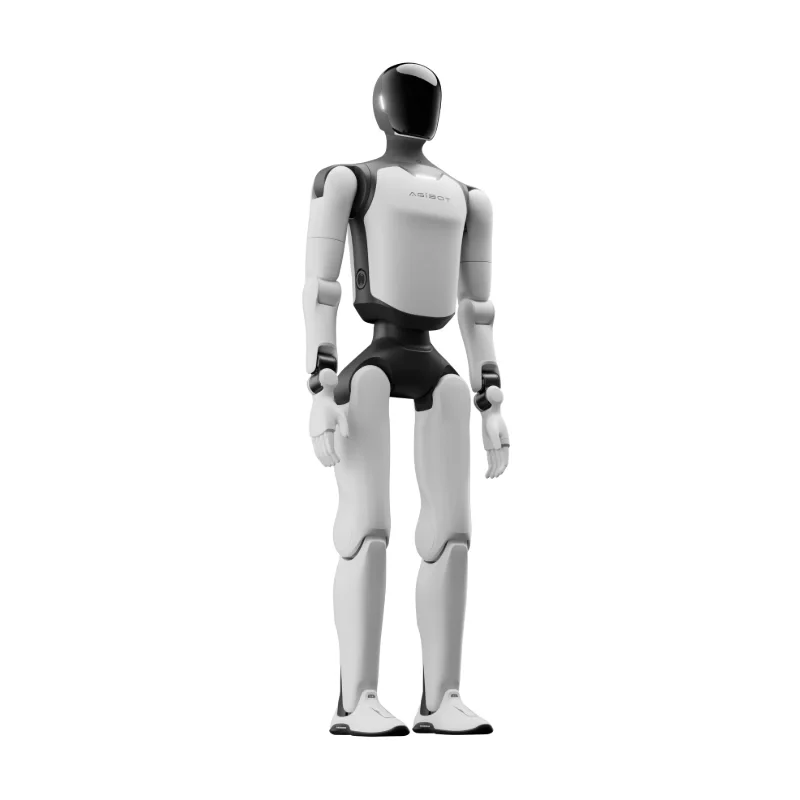
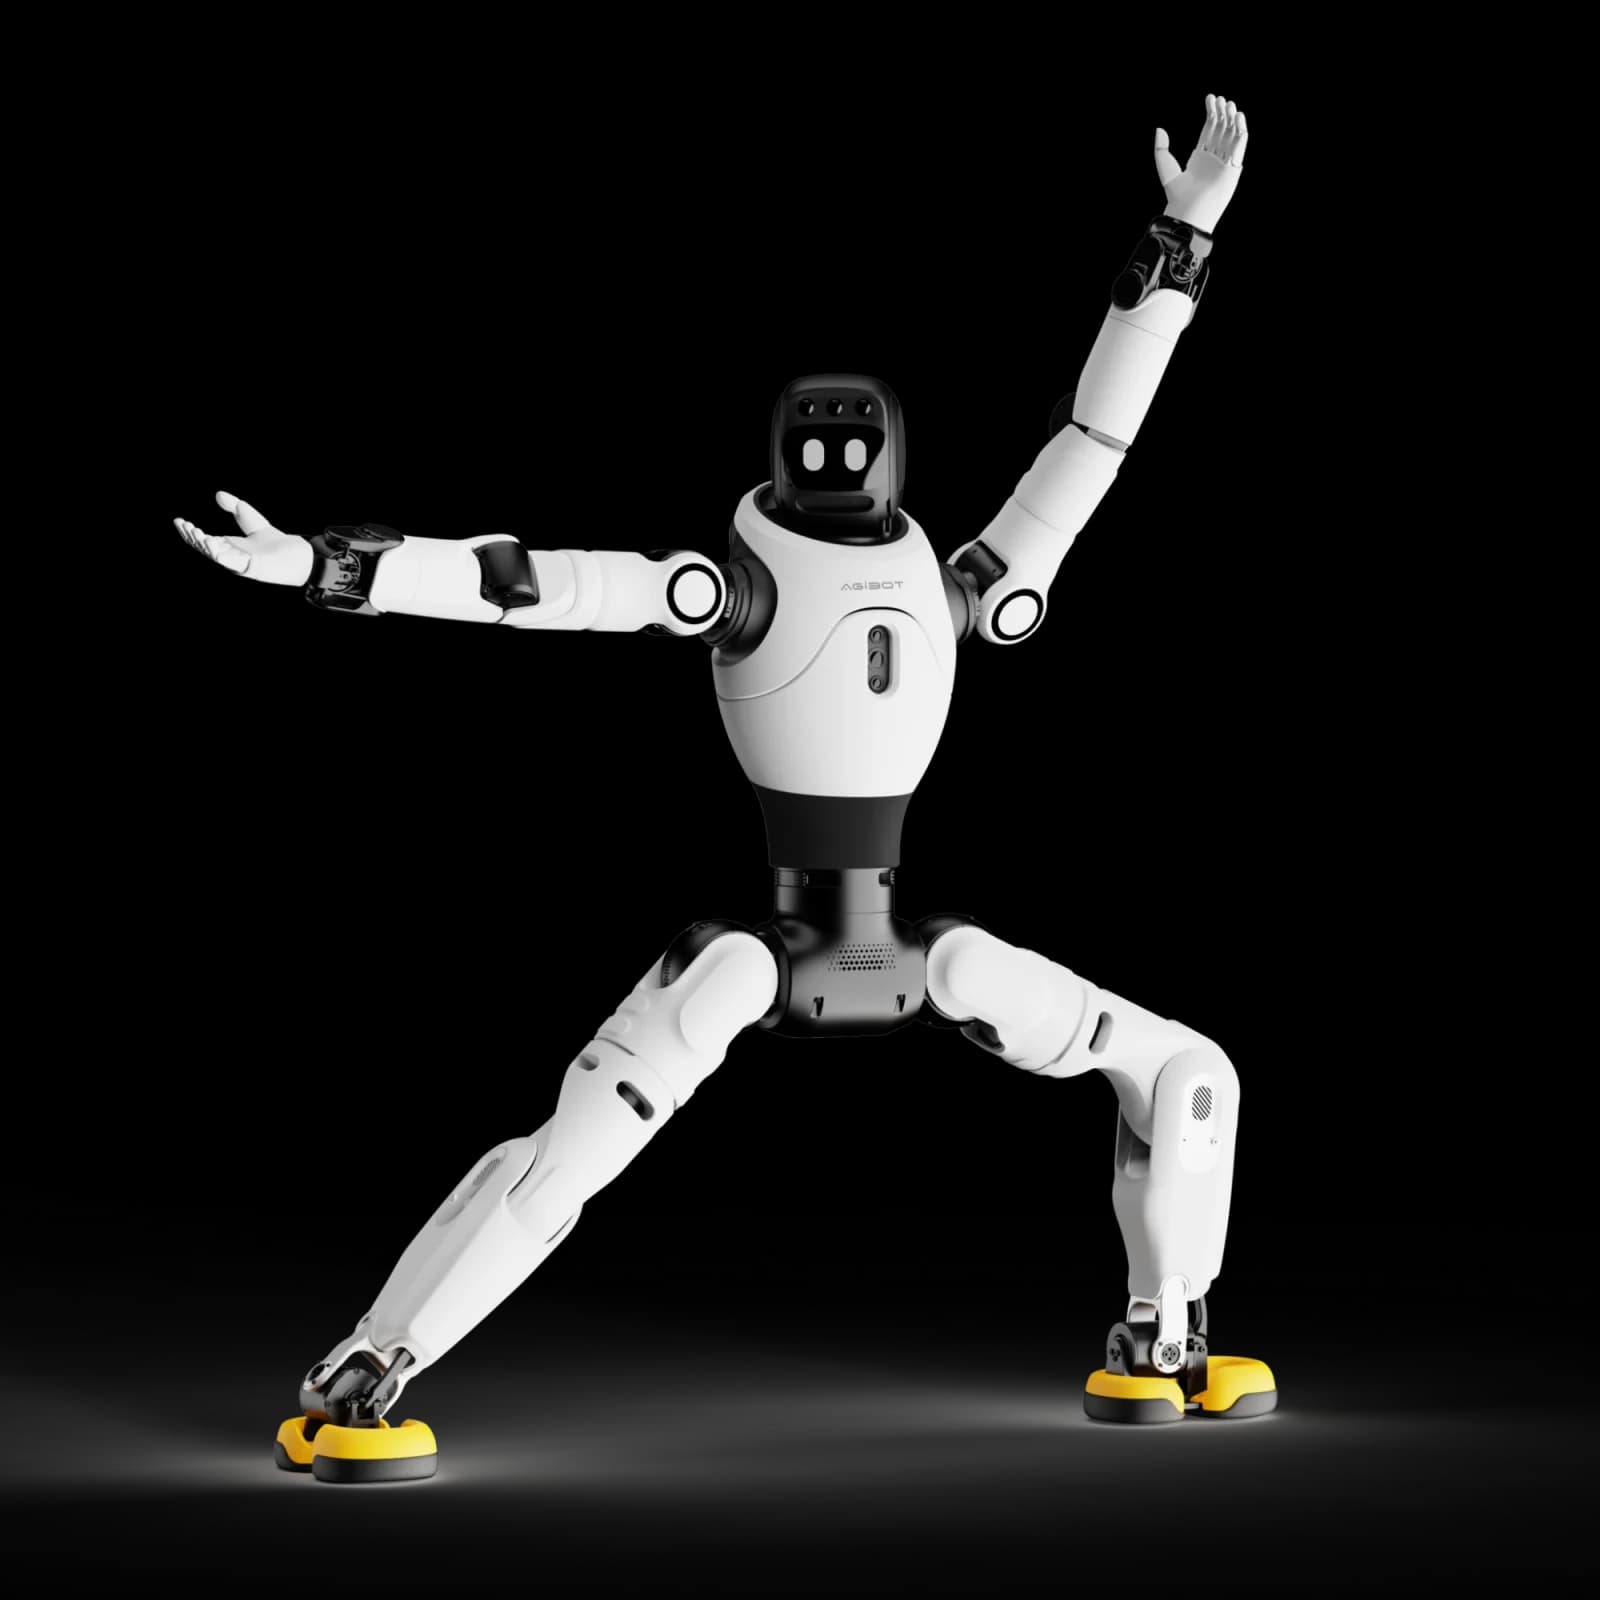
AGIBOT X2 Neo
Give performance and interaction projects a compact humanoid starting point. Neo's comparison does not support an SDK development path.
- Audio, display and head-touch interaction: consider the documented interaction channels for the project
- Interactive RGB camera: keep the interaction camera distinct from Ultra's development sensors
- SDK unsupported in the Neo comparison: identify the development boundary before choosing a configuration
For US delivery inquiries, include your state and intended use. We confirm configuration, pricing, availability and lawful supply before sending your quote or invoice.
A closer look.
Published specifications describe the cited manufacturer configuration. Your supplied configuration is confirmed in your quote.
- Mass
- Approximately 35 kg (Neo column)Source
- Active body degrees of freedom
- 30; one neck DOFSource
- Arm degrees of freedom
- 7 per armSource
- Typical walking speed
- ≤0.8 m/s (store comparison)Source
Configuration and reference notes
Neo has no high-performance development board, RGB-D or LiDAR in its comparison. Store records approximately 500 Wh and laboratory 2 m/s; development-model documentation records approximately 421 Wh and 1.8 m/s for its named variants, not verified Neo equivalents. Do not merge brochure base X2 (25 DOF, five per arm) with Neo (30, seven). Neo/Ultra share reference visuals; hands may be optional. Exact SKU and battery revision need confirmation.
Manufacturer reference tables.
Open the original parameter tables to compare documented versions. Source rows, units and conditions are retained; different versions are not merged into a promised configuration.
These are manufacturer references, not confirmation of your delivered hardware, warranty, field performance or event suitability. Final configuration and terms are agreed in your quote.
Manufacturer X2 / X2 Ultra comparison
Do not rename the source X2 column as Neo. Its body/arm DOF differ from the store Neo record.
Document:
Source model labels: X2 / X2 Ultra
Source location: HTML table index 0 (zero-based), all direct source rows; header spans retained
Source qualifications
- The base X2 column is a related reference, not proof of Neo equivalence.
On a small screen, swipe sideways within the table to compare columns.
| Item | X2 | X2 Ultra |
|---|---|---|
| Dimensions | 1310mm(H)× 460mm(W) × 210mm(L) | 1310mm(H) × 460mm(W) × 210mm(L) |
| Height | Approx.1.31 m | Approx.1.31 m |
| Weight | Approx.35kg | Approx.39kg |
| Total Degrees of Freedom | 25 | 30 |
| Neck DOF | 0 | 1 |
| Arm DOF (per arm) | 5 | 7 |
| Waist DOF | 3 | 3 |
| Leg DOF (per leg) | 6 | 6 |
| Arm Reach | 558mm excluding end effector | 558mm excluding end effector |
| Excluding end effector | -10℃ to 40℃ | -10℃ to 40℃ |
| Perception System | ||
| 3D LiDAR | Not equipped | Equipped |
| RGB-D Camera | Not equipped | Equipped |
| RGB Camera | Interactive RGB camera | Interactive RGB + Front dual RGB + Rear RGB |
| Head Touch Sensor | Equipped | Equipped |
| Communication | ||
| Communication | Wi-Fi, Bluetooth | Wi-Fi, Bluetooth 4G/5G module |
| Interaction Module | ||
| Audio I/O | Microphone array, wireless microphone, speaker | Microphone array, wireless microphone, speaker |
| Display | Interactive screen, lighting effects | Interactive screen, lighting effects |
| Performance Specifications | ||
| Peak Joint Torque | 120N·m | 120N·m |
| Walking Speed | Up to : 1.8 m/s typical ≤0.8 m/s Laboratory Environment: ≤2m/s | Up to : 1.8 m/s typical ≤0.8 m/s Laboratory Environment: ≤2m/s |
| Payload Capacity | Max (in specific postures): 3kg Excluding end effector Across full range: ≤1kg Excluding end effector | Max (in specific postures): 3kg Excluding end effector Across full range: ≤1kg Excluding end effector |
| Energy System | ||
| Battery Capacity | Approx.500Wh | Approx.500Wh |
| Operating Time | At 0.5 m/s walking Approx. 2 hours | At 0.5 m/s walking Approx. 2 hours |
| Power Supply Method | Direct charging, swappable battery | Direct charging, swappable battery |
| Charging Time | ≤1.5 hours | ≤1.5 hours |
| Input Voltage | 100~220V | 100~220V |
| Charger Output | 54.6V 10A | 54.6V 10A |
| Intelligent Control Specifications | ||
| Main Compute Board | RK3588 ×2 | RK3588 ×2 |
| High-performance Board | Not equipped | Orin NX (157 TOPS) |
| Hardware Expansion Interface | ||
| USB Ports | Type-A ×1 Type-C ×1 | Type-A ×2 Type-C ×2 |
| LAN Ports | / | RJ45 ×2 |
| Power Output | 12V/3A ×1 48V/5A ×1 | 12V/3A ×1 48V/5A ×1 |
| Others | ||
| Handheld Controller | Option | Option |
| OTA Updates | Supported | Supported |
| Mobile App | Supported | Supported |
| Secondary Development | Not supported | Supported |
Manufacturer reference only. This table does not establish the delivered configuration, inclusions, certification, warranty, field performance or event suitability. Preserve source conditions and footnotes when displaying it.
Open manufacturer sourceAGIBOT X2 Neo — retained store comparison
Document:
Source model labels: AGIBOT X2 Neo
Source location: Specifications Comparison; .product-modal-text index 0; all labeled paragraphs
Source qualifications
- Store lists approximately 500Wh and laboratory 2m/s, not AimDK 421Wh / 1.8m/s. New-Version store ports differ from AimDK new-version ports. Included/Equipped/Supported text is source-reference text, not a delivered-kit guarantee.
| Dimensions | 1310mm (H) × 460mm (W) × 210mm (L) |
|---|---|
| Height | Approx. 1.31 m |
| Weight | Approx. 35kg |
| Total Degrees of Freedom | 30 |
| Neck DOF | 1 |
| Arm DOF (per arm) | 7 |
| Waist DOF | 3 |
| Leg DOF (per leg) | 6 |
| Arm Reach | 558mm (excluding end effector) |
| Operating Temperature | -10℃ to 40℃ |
| 3D LiDAR | Not equipped |
| RGB-D Camera | Not equipped |
| RGB Camera | Interactive RGB camera |
| Head Touch Sensor | Equipped |
| Communication | Wi-Fi, Bluetooth, 4G/5G module |
| Audio I/O | Microphone array, wireless microphone, speaker |
| Display | Interactive screen, lighting effects |
| Peak Joint Torque | 120·Nm |
| Walking Speed | Up to * 2 m/s, typical ≤ 0.8 m/s * Measured under laboratory conditions. |
| Payload Capacity | Max (in specific postures): 3kg, Across full range: ≤ 1kg (excluding end effector) |
| Battery Capacity | Approx. 500Wh |
| Operating Time | At 0.5 m/s walking, Approx. 2 hours |
| Power Supply Method | Direct charging, swappable battery |
| Charging Time | ≤ 1.5 hours |
| Input Voltage | 100~220V |
| Charger Output | 54.6V 10A |
| Main Compute Board | RK3588 x2 |
| High-performance Board | Not equipped |
| USB Ports | Type-A x1, Type-C x1 |
| LAN Ports | / |
| Video Output | None |
| Power Output | 12V/3A x1, 48V/5A x1 |
| Handheld Controller | Included |
| OTA Updates | Supported |
| Mobile App | Supported |
| Secondary Development | Not supported |
Manufacturer conditions and footnotes
- * Measured under laboratory conditions.
Manufacturer reference only. This table does not establish the delivered configuration, inclusions, certification, warranty, field performance or event suitability. Preserve source conditions and footnotes when displaying it.
Open manufacturer sourceBrochure — AGIBOT X2 — complete Specifications grid
Document: AGIBOT-Product-Brochure-20260722.pdf
Source model labels: AGIBOT X2
Source location: physical PDF page 12
Source qualifications
- Related base X2 reference only: manufacturer prints 25 DOF / 5 per arm. This is not a Neo specification or alias.
| Height | 131 cm |
|---|---|
| Weight | 35 kg |
| Intelligent Perception | Interactive RGB Camera |
| Total DOFs | 25 |
| DOFs per Arm | 5 |
| Max End Effector Payload | 3 kg |
| Max Walking Speed | 2 m/s |
| Battery Capacity | 500 Wh |
| Endurance | 2 h |
| Proactive Interaction | Supported |
| Computing Module | RK3588 (motion control) RK3588S (interaction) |
| Built-in Motion Skills | Yes |
Manufacturer reference only. This table does not establish the delivered configuration, inclusions, certification, warranty, field performance or event suitability. Preserve source conditions and footnotes when displaying it.
Open manufacturer source — page 12From the right configuration to a clear quote.
Tell us your model, intended use and timeline. We review the accessories and delivery requirements with you, then send a quote or invoice for the agreed configuration.
Start an inquiry- Share your requirements
Model, intended use and timeline.
- Review the configuration
Accessories, compatibility and delivery.
- Receive your quote
Agreed scope before a quote or invoice.